Humans possess a ‘seventh sense’ that detects hidden objects
Human fingers sensed tiny disturbances in sand before reaching a hidden cube, outperforming a robot in overall detection precision.
 Edited By: Joshua Shavit

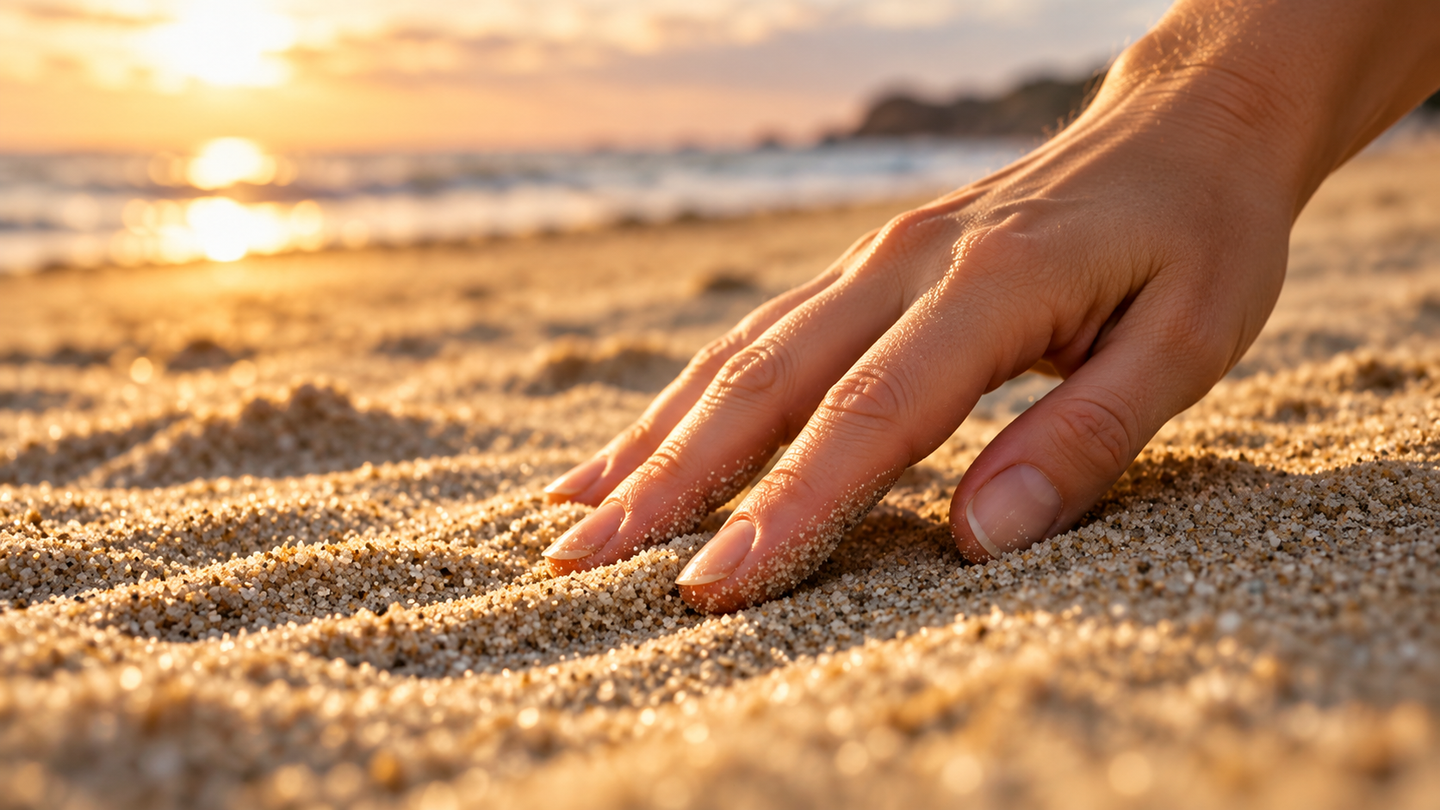
People detected buried objects through sand before contact, revealing a previously undocumented form of remote touch in humans. (CREDIT: The Brighter Side of News)
- Researchers found that people can detect a buried object in sand before their finger physically touches it, providing the first experimental evidence of “remote touch” in humans.
- Twelve participants detected a hidden cube within an average theoretical range of about 6.9 centimeters, achieving 70.7% precision and statistically significant sensitivity above chance.
- A robotic tactile system could sometimes detect the object from farther away, but produced more false positives, suggesting that human touch remains better calibrated for deciding when a hidden object is actually present.
Touch is usually considered a contact sense. You feel an object because your skin presses against it, slides across it or receives vibrations directly from its surface.
A new experiment suggests human touch can reach farther than that.
Researchers from Queen Mary University of London and University College London found that people moving their fingers through sand could detect a buried object before making physical contact with it. The ability resembles a form of “remote touch” previously documented in shorebirds that probe sediments for hidden prey.
The study, published in the journal IEEE Xplore, compared people with a robotic tactile system trained to perform a similar task. Humans proved surprisingly sensitive to tiny disturbances traveling through the sand, approaching the physical range predicted by models of how granular material shifts around buried objects.
The findings provide the first quantitative evidence for this kind of remote tactile detection in humans and could eventually influence robots designed for archaeology, search and rescue, marine exploration and planetary missions.
Touch can travel through moving sand
Sand may appear loose and simple, but its grains transmit forces in complicated ways.
When a finger moves through sand, grains ahead of it are displaced, compressed and rearranged. That disturbance can spread outward through networks of particles known as force chains. If those moving grains encounter a solid buried object, the pattern of resistance can change before the finger reaches the object itself.
Shorebirds such as sandpipers and plovers appear to exploit related physical effects while searching sediments for prey. Researchers wanted to know whether the human nervous system could also detect such subtle mechanical changes despite lacking the birds’ specialized beaks.
“Tactile perception is usually considered a proximal sense,” the researchers wrote, meaning it normally depends on direct contact. Their experiments instead tested whether people could extract information from disturbances propagating through an intermediate material.
The team recruited 12 participants between 18 and 26 years old. Each person moved an index finger through a long box containing dry sand while trying to determine whether a hidden cube lay ahead.
Participants searched without seeing the object
The experimental box measured more than a meter long and contained a 7-centimeter layer of fine dry sand. A 5-centimeter cube could be fixed at one of four positions, while some trials contained no object at all.
Visual information was blocked, and participants slid their fingers through a narrow opening in the box lid. A blinking LED strip guided their movement at about 2 centimeters per second so each trial followed a similar speed.
Participants were instructed to stop as soon as they believed they sensed the buried cube.
Each completed 18 testing trials after an initial familiarization period. Across the group, the researchers collected 216 trials, including 144 with an object and 72 without one.
The team then compared where participants stopped with the expected physical region in which their fingers could disturb the sand surrounding the cube.
A granular-physics model predicted an average human detection zone of about 6.9 centimeters in front of the object.
Humans performed significantly better than chance
The results showed that the participants were not simply guessing.
Among the 144 trials containing a buried cube, 79 stops occurred before direct contact but within the expected detection zone. Another 35 occurred within 2 centimeters of the cube and were treated conservatively as contact rather than remote detection.
In the trials without an object, participants correctly continued through the box 58 times, while 14 trials produced false alarms.
A signal-detection analysis produced an average sensitivity score, known as d-prime, of 1.1973. That result differed significantly from zero, with a probability value of 0.0004, indicating that participants could reliably distinguish object-present from object-absent conditions.
The analysis also found no significant overall response bias. Participants were not simply stopping early because they expected an object to be there.
Their overall precision was 70.7%.
The median pre-touch detection distance was about 2.7 centimeters, although some detections occurred farther away. The findings show that humans can perceive subtle changes in granular forces before the skin reaches the buried object itself.
A robot could reach farther but made more mistakes
The researchers then created a robotic version of the experiment.
A UR5 robotic arm carried a custom tactile sensor designed to mimic a human finger moving through the same type of sand. Four sensing elements measured forces along three axes while the robot raked toward the hidden cube.
The tactile system collected data at about 135 samples per second. Researchers trained Long Short-Term Memory, or LSTM, neural networks to recognize patterns indicating when an object was nearby.
Different models were trained using assumed detection thresholds ranging from 3 to 11 centimeters. The 7-centimeter version most closely matched the theoretical human detection range.
That robotic model often detected the cube earlier than people. Its median detection distance was 6 centimeters, while its estimated physical range was about 7.1 centimeters.
However, it also produced many more false positives.
The robot achieved only 40% precision in the comparison used by the researchers, versus 70.7% for the human participants. The system was highly sensitive to disturbances but struggled to determine which disturbances genuinely indicated a buried object.
Human perception may be better calibrated than raw sensors
The contrast suggests an important difference between detecting tiny mechanical signals and interpreting them correctly.
A robotic sensor can register extremely small force variations, but human perception combines incoming tactile information with a nervous system adapted to filter noise, weigh uncertainty and make decisions about ambiguous sensations.
That may explain why the robot sometimes detected objects from farther away but was less reliable overall.
“What makes this research especially exciting is how the human and robotic studies informed each other,” said Lorenzo Jamone of University College London. “The human experiments guided the robot’s learning approach, and the robot’s performance provided new perspectives for interpreting the human data.”
The work could eventually improve machines designed to search environments where cameras cannot help. Tactile robots might probe soil for archaeological objects, search rubble after disasters or explore granular terrain on the Moon, Mars or the ocean floor.
For humans, the result also expands the traditional boundaries of touch.
“It’s the first time that remote touch has been studied in humans,” said Elisabetta Versace of Queen Mary University of London. The findings suggest that the tactile receptive field may sometimes extend beyond the skin itself, through the physical medium connecting the hand with an unseen object.
Dig deeper into touch, granular physics and tactile robotics
These resources provide broader context on tactile sensing, granular materials and bio-inspired robotic perception.
Granular media: Some ideas from statistical physics: This review explains how force chains, jamming and collective grain behavior make materials such as sand behave in unexpectedly complex ways. (Physica A, 1999)
Jamming at zero temperature and zero applied stress: The epitome of disorder: This influential paper examines how granular materials transition between flowing and rigid states, a key part of understanding force transmission through sand. (Physical Review E, 2003)
The human sense of touch and its neurophysiological basis: This review describes how skin mechanoreceptors detect pressure, vibration and shear and how those signals are processed by the nervous system. (Nature Reviews Neuroscience, 2016)
A review of tactile sensing technologies with applications in biomedical engineering: This review covers modern tactile sensors and how engineers attempt to reproduce aspects of human touch in robotic systems. (Sensors and Actuators A: Physical, 2020)
Soft robotic sensing: technologies and system integration: Researchers review tactile and force-sensing approaches designed to give robots more adaptable and biologically inspired perception. (NPG Asia Materials, 2020)
Research findings are available online in the journal IEEE Xplore.
The original story "Humans possess a ‘seventh sense’ that detects hidden objects" is published in The Brighter Side of News.
Related Stories
- Scientists discover how our sixth sense really works
- Seeds can sense the sound of falling raindrops, MIT study finds
- Your eyes and emotions help shape your sense of temperature, study finds
Like these kind of feel good stories? Get The Brighter Side of News' newsletter.
Joseph Shavit
Writer, Editor-At-Large and Publisher
Joseph Shavit, based in Los Angeles, is a seasoned science journalist, editor and co-founder of The Brighter Side of News, where he transforms complex discoveries into clear, engaging stories for general readers. With vast experience at major media companies like The Los Angeles Times, Times Mirror and Tribune Publishing, he writes with both authority and curiosity. His writing focuses on space science, planetary science, quantum mechanics, geology. Known for linking breakthroughs to real-world markets, he highlights how research transitions into products and industries that shape daily life.