Scientists develop a way to capture space junk using robots and spinning magnets
Scientists demonstrated a contactless way to move and rotate conductive objects that could someday help robots safely handle space junk.
 Edited By: Joshua Shavit

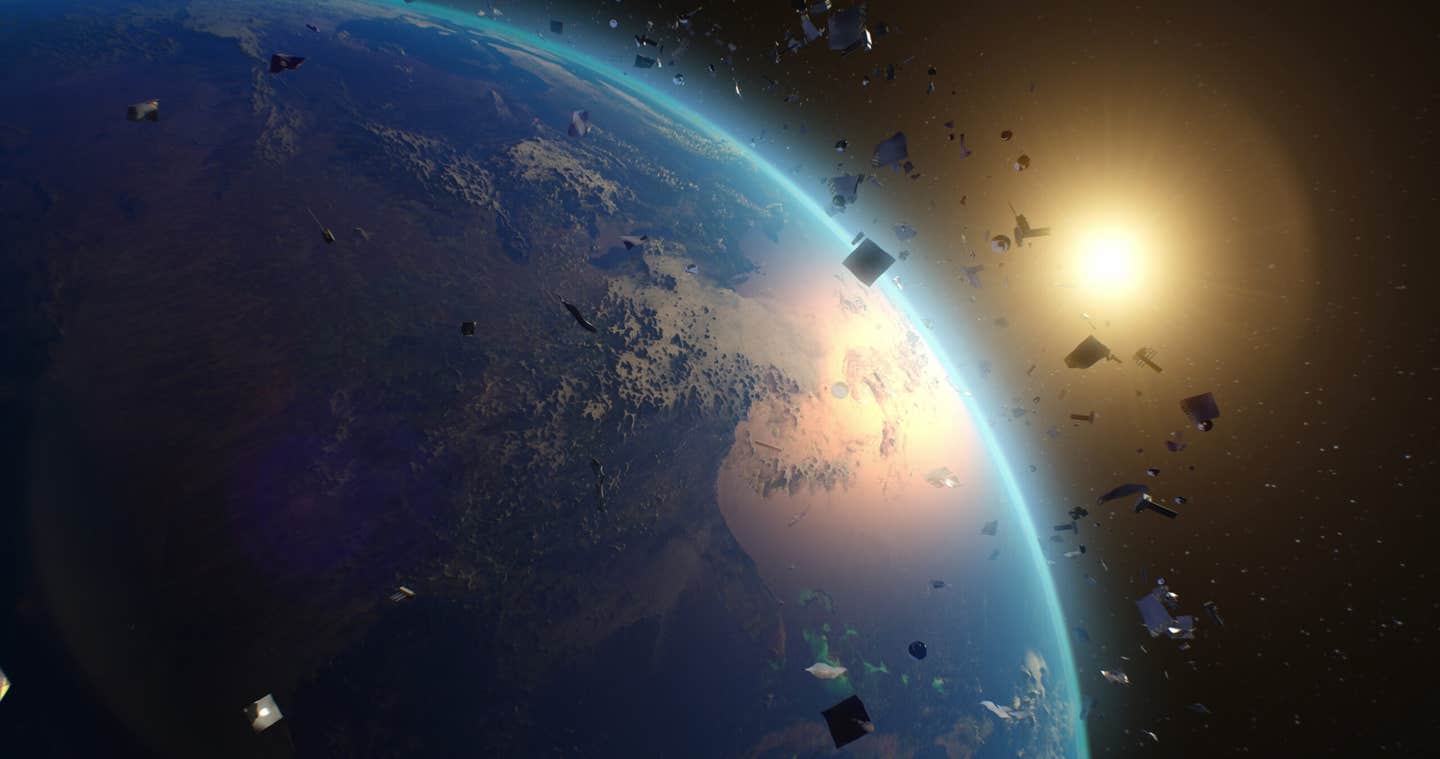
Thousands of dead satellites, spent rocket components and fragments of spacecraft circle Earth at tremendous speeds. (CREDIT: Shutterstock)
- Researchers have demonstrated a way to move electrically conductive but nonmagnetic objects without touching them, using coordinated rotating magnetic fields to generate forces and torques through eddy currents.
- The technique achieved six-degree-of-freedom control in microgravity simulations and three-degree-of-freedom experimental control, suggesting future robots could potentially stabilize, reposition or service tumbling pieces of space hardware.
- Because much orbital debris contains conductive aluminum, the method could eventually help spacecraft approach dangerous objects more gently than mechanical grabbing systems, although the current experiments remain an early proof of concept rather than a flight-ready cleanup technology.
Thousands of dead satellites, spent rocket components and fragments of spacecraft circle Earth at tremendous speeds. Trying to grab one of those objects with a robotic arm could turn a cleanup mission into another collision.
A different strategy could allow a spacecraft to control the debris before making contact with it.
Researchers at the University of Utah demonstrated that coordinated rotating magnetic fields can push, pull and rotate conductive objects even when those objects are not magnetic. The method exploits electrical currents generated inside metals such as copper and aluminum and could eventually give orbital robots a way to stabilize tumbling debris from a distance.
The work, published in Nature as “Dexterous magnetic manipulation of conductive non-magnetic objects,” was led by University of Utah mechanical engineering professor Jake J. Abbott and colleagues Lan Pham, Griffin Tabor, Ashkan Pourkand, Jacob L. B. Aman and Tucker Hermans.
“What we wanted to do was to manipulate the thing, not just shove it but actually manipulate it like you do on Earth,” Abbott said. “That form of dexterous manipulation has never been done before.”
Space debris can be extremely difficult to grab
The danger posed by orbital debris comes partly from speed. Objects in low Earth orbit can travel at roughly 17,500 mph, meaning even relatively small fragments can strike operating spacecraft with enormous energy.
Cleaning up larger debris presents a different challenge. Defunct satellites and rocket stages may be tumbling, lack functioning attitude-control systems and provide no cooperative docking mechanism for an approaching spacecraft.
A robotic arm cannot safely grab an object if it is spinning unpredictably. Contact at the wrong time could damage the servicing spacecraft, break the robot arm or fragment the target, potentially creating still more debris.
“You have to take this crazy object floating in space, and you have to get it into a position where it can be manipulated by a robot arm,” Abbott said. “But if it’s spinning out of control, you could break the robot arm doing that, which would just create more debris.”
Contactless control could therefore provide an important intermediate step. A cleanup or servicing spacecraft could first reduce an object's rotation, adjust its orientation or maneuver it into a more favorable position before attempting mechanical capture.
A changing magnetic field turns metal into part of the system
The University of Utah approach relies on eddy currents, which form when a conductor experiences a changing magnetic field. Electrons begin circulating through the metal, creating their own magnetic fields.
Abbott compared the circulating motion to swirling liquid around a cup.
Those induced currents interact with the magnetic field that created them, producing forces and torques on the object. Aluminum is especially relevant because it is common in spacecraft construction while remaining nonmagnetic under ordinary conditions.
Previous proposals had already explored using eddy currents to slow rotating space objects or apply forces in limited directions. The new work addressed a more ambitious problem: whether several rotating magnetic-field sources could be coordinated to control both an object's position and orientation.
The researchers developed mathematical models describing how forces and torques appear when a conductive sphere sits in different positions relative to a rotating magnetic dipole. They combined dimensional analysis with electromagnetic simulations and laboratory measurements to characterize the interaction.
Six degrees of freedom offer much greater control
An object moving freely through space has six degrees of freedom. It can translate along three axes and rotate around three axes.
Being able to control all six is important for precise manipulation. A system that only pushes an object away, for example, cannot necessarily stop a satellite from tumbling or line up one side of it with a robotic repair system.
The team showed in numerical microgravity simulations that six rotating magnetic-dipole sources surrounding a conductive sphere could control all six degrees of freedom. The simulations could move the sphere through three-dimensional space while also controlling its orientation.
Their experimental setup reproduced a smaller portion of that capability on Earth. Four electromagnetic devices called Omnimagnets were positioned beneath a container of water, while a copper sphere floated on a raft above them.
The water reduced the effects of ordinary friction and allowed the sphere to move slowly in a horizontal plane, serving as an Earth-based approximation of some microgravity behavior.
Researchers successfully guided the sphere around a square path and also controlled its orientation. The experiments demonstrated two degrees of positional control plus one rotational degree of freedom.
The magnets never need to grab the debris
Contactless manipulation offers several potential advantages beyond dealing with spinning objects. Mechanical claws concentrate forces at the points where they touch a target, which can be problematic if an aging satellite has fragile structures, thin panels or damaged components.
Magnetically induced eddy currents distribute forces through the conductive material. That could allow gentler manipulation without attaching a clamp or docking fixture directly to the target.
The concept could also contribute to orbital servicing rather than simply disposal. A spacecraft might stabilize a malfunctioning satellite so a robot could inspect, repair or reposition it, potentially extending the satellite's useful life.
Alternatively, a debris-removal vehicle could help orient an object before attaching another system that sends it toward a controlled reentry trajectory.
The researchers describe several possible ways to generate the necessary fields. These could include rotating permanent magnets, stationary electromagnets capable of generating rotating fields or superconducting electromagnetic systems.
A space cleanup system remains far from ready
The experiments do not demonstrate a practical orbital debris-removal spacecraft. The physical tests used a simple solid copper sphere, while real satellites and rocket components have complex shapes, hollow structures and mixtures of materials.
The magnetic forces are also relatively weak compared with forces achievable when directly manipulating strongly magnetic materials. The researchers noted that the method therefore produces comparatively slow movements.
Their model initially focused on solid spheres because their geometry makes the physics easier to describe. Extending control to hollow spheres, cylinders, boxes and irregular pieces of spacecraft hardware will require more sophisticated modeling and experimentation.
The arrangement of field sources also remains an open engineering question. Six sources were sufficient for six-degree-of-freedom control in the numerical experiment, but that does not establish the minimum number or the best configuration for an actual spacecraft.
Still, the work introduces a different way of thinking about orbital interaction. Instead of racing toward a tumbling satellite and trying to seize it immediately, a robot could potentially begin controlling it while remaining physically separated.
“I’m starting to open my mind to what potential applications there are,” Abbott said. “We have a new way to apply a force to an object for precise alignment without touching it.”
As Earth's orbital environment grows more crowded, that ability could become increasingly valuable. The safest way to grab some pieces of space junk may ultimately be to make them stop fighting first.
Dig deeper into contactless space-debris control
These resources examine orbital-debris removal, eddy-current manipulation and technologies designed to stabilize uncontrolled spacecraft before capture.
Review and comparison of active space debris capturing and removal methods: Reviews major approaches for capturing and removing noncooperative debris and the challenge of avoiding additional fragmentation during cleanup missions. (Progress in Aerospace Sciences, 2016)
Prospects of using a permanent magnetic end effector to despin and detumble an uncooperative target: Investigates rotating permanent-magnet arrays as a contactless method for reducing the rotation of uncontrolled satellites through induced eddy currents. (Advances in Space Research, 2018)
Active debris removal: Recent progress and current trends: Surveys active debris-removal concepts and the engineering challenges involved in safely approaching, capturing and disposing of large orbital objects. (Acta Astronautica, 2013)
New Electromagnetic Actuator for On-Orbit Inspection: Explores an eddy-current actuator that could generate contactless force and torque between an inspection spacecraft and a conductive target. (Journal of Spacecraft and Rockets, 2016)
A slowly rotating hollow sphere in a magnetic field: First steps to de-spin a space object: Examines how magnetic fields can induce eddy-current torque in conductive orbital objects, providing an earlier foundation for contactless satellite detumbling. (American Journal of Physics, 2016)
Research findings are available online in the journal Nature.
The original story "Scientists develop a way to capture space junk using robots and spinning magnets" is published in The Brighter Side of News.
Related Stories
- Astronomers are finding space junk too small to track, and it's getting dangerous
- Scientists build an electrostatic 'tractor beam' to move space junk safely
- Solving space junk with lessons from ocean pollution cleanup
Like these kind of feel good stories? Get The Brighter Side of News' newsletter.
Joseph Shavit
Writer, Editor-At-Large and Publisher
Joseph Shavit, based in Los Angeles, is a seasoned science journalist, editor and co-founder of The Brighter Side of News, where he transforms complex discoveries into clear, engaging stories for general readers. With vast experience at major media companies like The Los Angeles Times, Times Mirror and Tribune Publishing, he writes with both authority and curiosity. His writing focuses on space science, planetary science, quantum mechanics, geology. Known for linking breakthroughs to real-world markets, he highlights how research transitions into products and industries that shape daily life.